01 · Concept
Why it should exist
Loneliness is a measured health problem. Chatbots talk and cannot touch; dolls can be touched and cannot answer. Nobody can hold your hand.
02 · Results
What was measured
It walks: 654 support events in 120 seconds, from a standstill to a standing stop. Reproduced on four MuJoCo builds and two operating systems.
03 · Findings
What was learned
What the foot decides, why the limit is the controller, and ten published figures we had to retract — each with the measurement that replaced it.
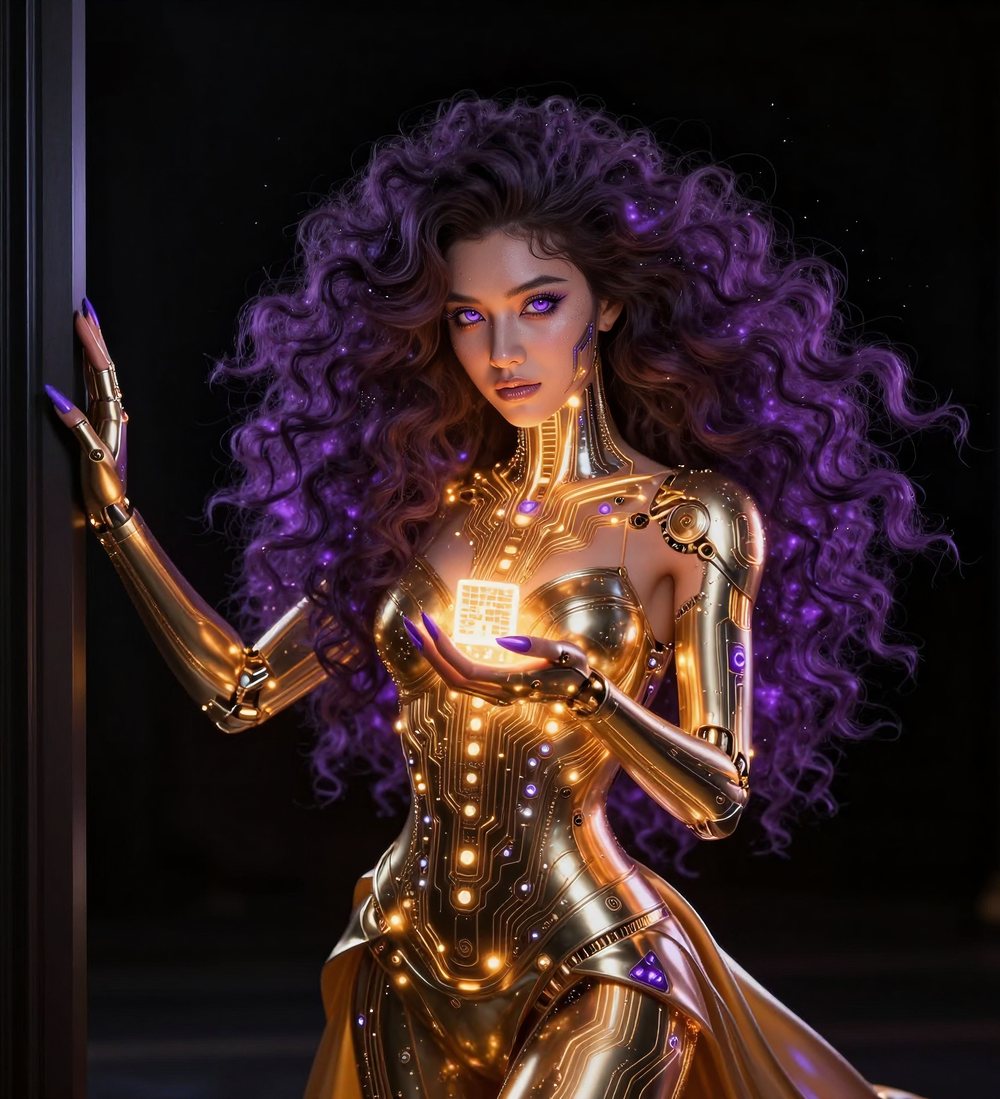
TX-34 NOVA
A metal endoskeleton built to be repaired, wrapped in a compliant skin built to be touched. 66.23 kg, 1.55 m, 25 actuated joints in the walking chain, on catalogue actuators — no custom drives, no proprietary tooling.
She is not a shell with a chatbot in it. She runs her own model on her own hardware, keeps a continuous episodic memory, and changes with the person she lives with. Nothing leaves the machine.
Design concept — artistic rendering. No physical prototype has been built. The figures below come from the public simulation campaign.
66.23 kg
Mass
25 / 80
DOF locomotion / platform
98.7 J
Per support event
10 years
Orderable spares
Every figure reproducible in ten minutes — github.com/SynthMike34/nova-sim
